
 Repository
Current collected state Current
Observed since 20 Oct, 18:14 UTC
No superseded metadata states collected. Unchanged observations do not create new revisions.
Adaptive Perception Control — minimize vision compute cost while maintaining decision accuracy
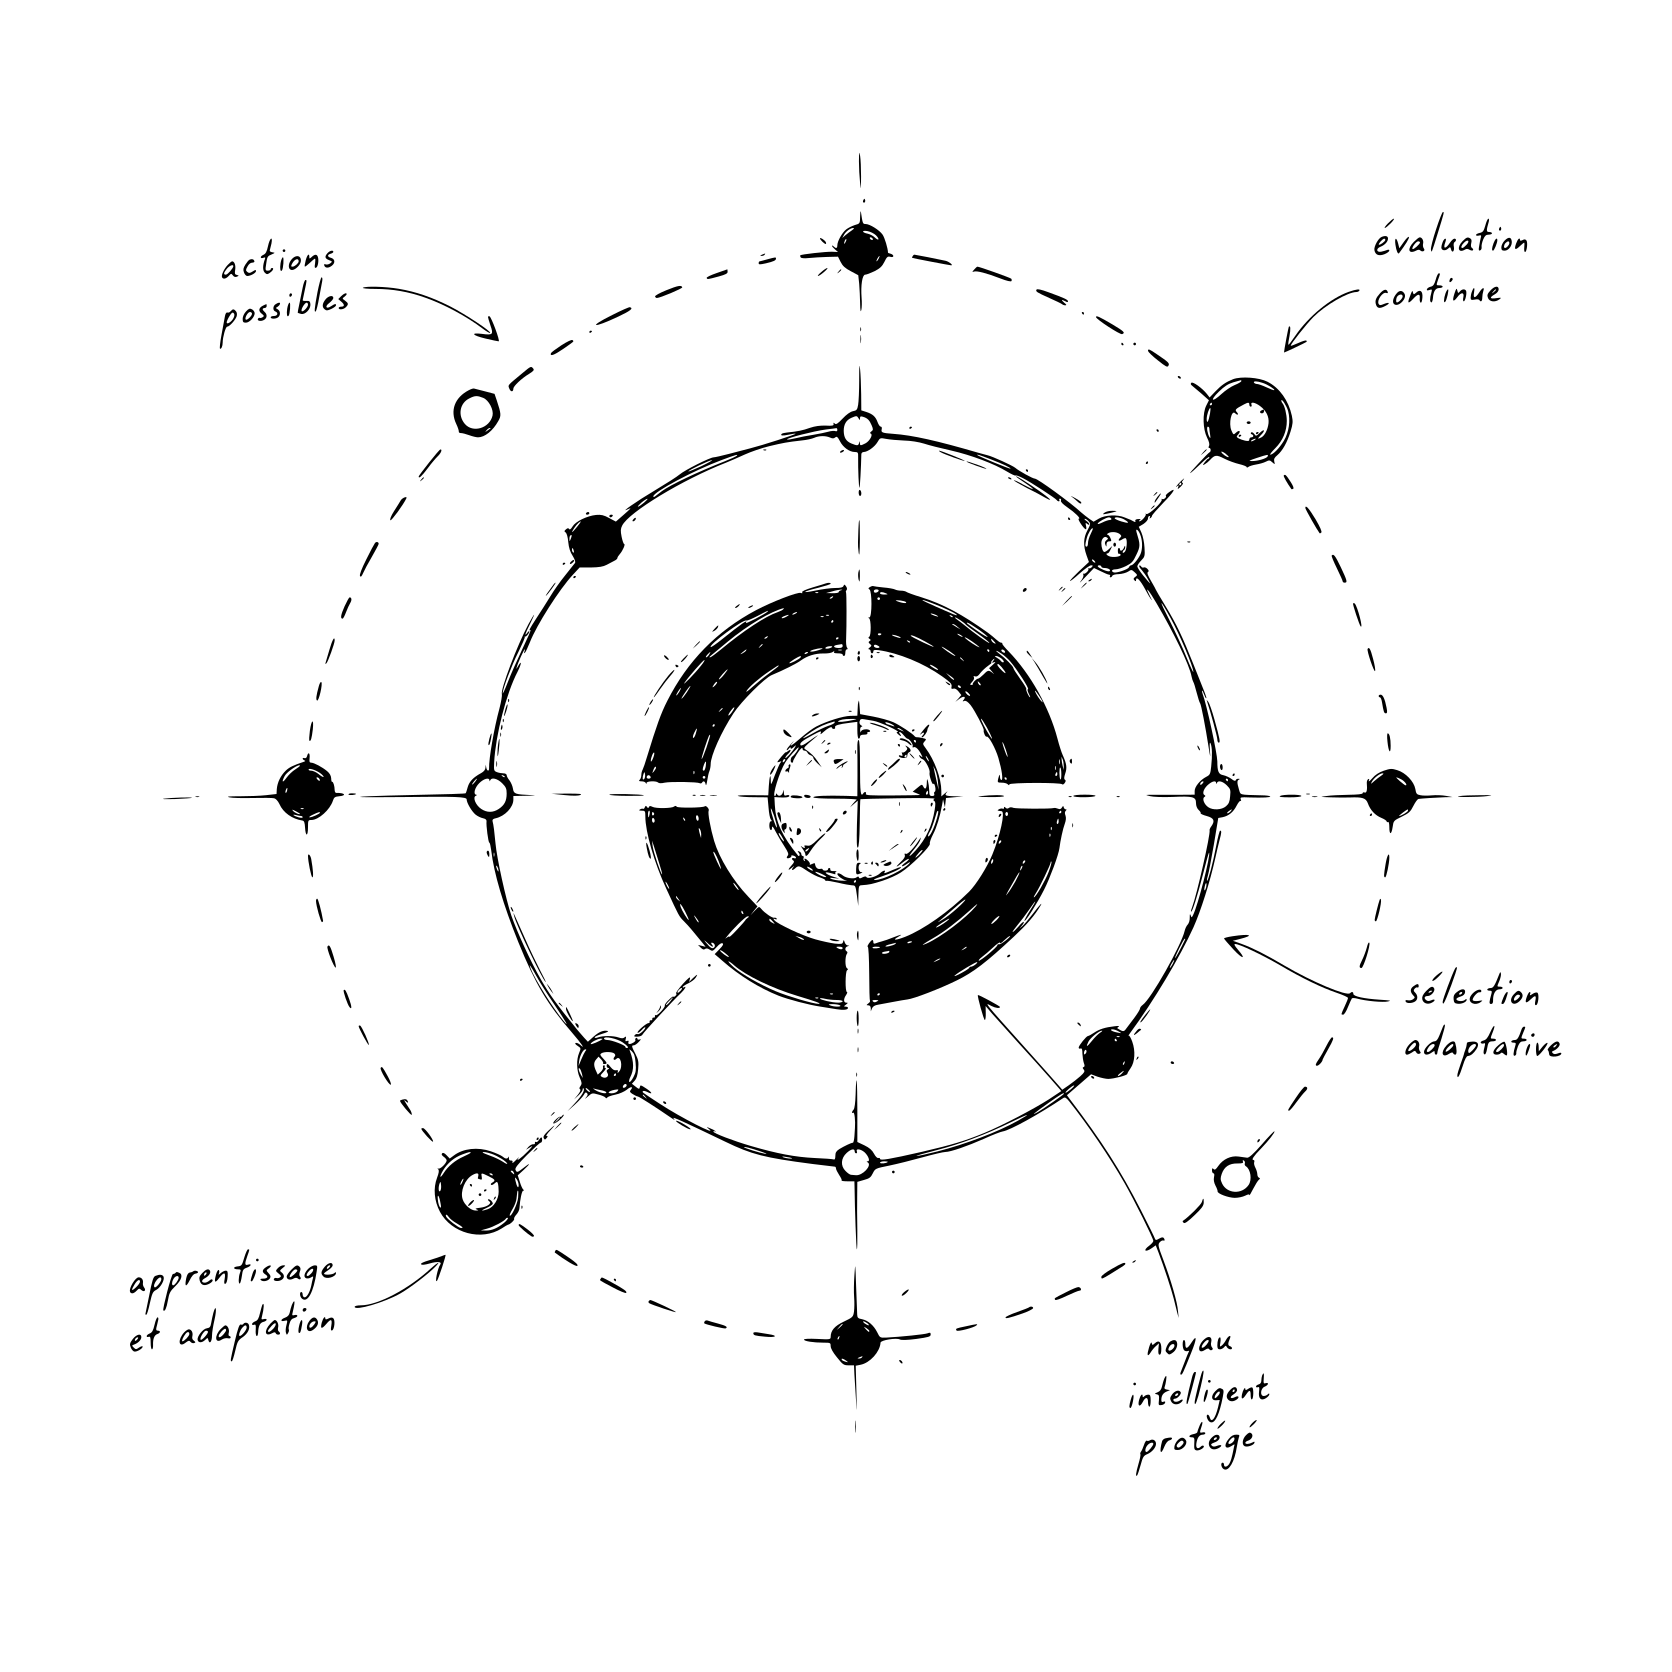
A decision-theoretic framework for adaptively controlling visual perception to minimize computational cost while maintaining target decision risk.
Perception is not a fixed pipeline. It is a resource to control.
Every perception system wastes resources processing information that doesn't change the decision. ACIES solves this by treating perception as a cost-risk optimization problem.
| Without ACIES | With ACIES | |
|---|---|---|
| Resolution | Fixed (max) | Adaptive (optimal) |
| Cost | 385.8 | 93.6 |
| Accuracy | 98.8% | 90.8% |
| Savings | — | 76% |
Trade 8% accuracy for 76% cost reduction. Or tune the threshold to find your own sweet spot.
from acies import APCController, APCConfig, HardwareProfile

apc = APCController(APCConfig(
    confidence_threshold=0.92,
    hardware=HardwareProfile.jetson_orin(),
))

def clarity_fn(action):
    clarities = {
        "64p": 0.55, "128p": 0.65, "224p": 0.75,
        "320p": 0.82, "512p": 0.88, "1024p": 0.93,
        "crop_224": 0.85, "crop_320": 0.90, "crop_512": 0.92,
    }
    return clarities.get(action.name, 0.5)

result = apc.run(true_class=1, clarity_fn=clarity_fn)
print(f"Decision: {result.decision} | Cost: {result.total_cost:.1f} | Steps: {result.n_steps}")
go build -o acies-cli .

./acies-cli run --hardware jetson --verbose
./acies-cli bench --iterations 5000 --hardware rpi
docker build -t acies .
docker run acies bench --iterations 1000
git clone https://github.com/NICE-DEV226/ACIES.git
cd ACIES
| Component | Command | Notes |
|---|---|---|
| Python | (none) | stdlib only, zero deps |
| C++ accelerator | cd cpp && make | Optional, 3-5x speedup |
| Go CLI | go build -o acies-cli . | Single binary |
| Docker | docker build -t acies . | Multi-stage, all-in-one |
Verify:
python3 test_apc.py          # 8/8 tests
./acies-cli version          # ACIES v0.1.0
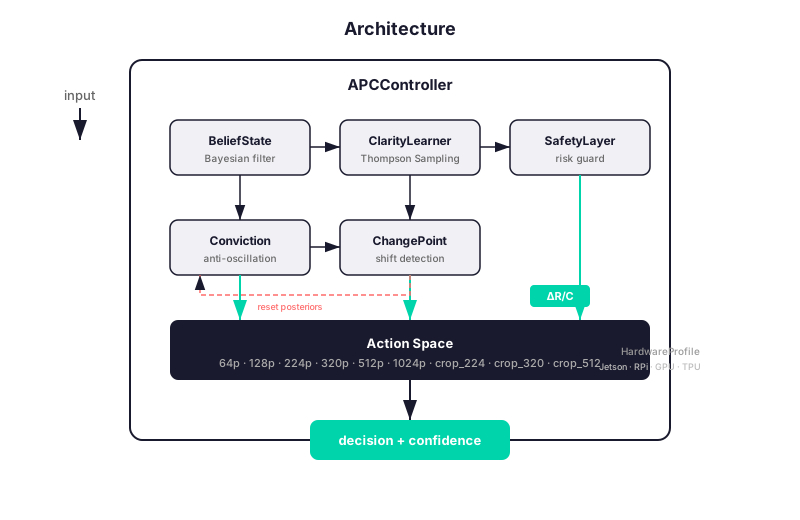
Control loop: Sample → Score (ΔR/C) → Adjust → Filter → Execute → Observe → Update → Repeat
| Step | Component | What it does |
|---|---|---|
| 1 | Belief Tracking | Maintains P(Y=1 | observations) via Bayesian filtering |
| 2 | Clarity Estimation | Thompson Sampling learns P(correct | action) online |
| 3 | Action Scoring | Computes ΔR/C (risk reduction per cost) for each action |
| 4 | Conviction | Anti-oscillation boosts high-clarity actions near threshold |
| 5 | Safety Filtering | Rejects actions that could exceed risk threshold |
| 6 | Change-Point Detection | Resets posteriors on distribution shifts |
| 7 | Decision | Stops when confidence ≥ threshold or max steps reached |
python3 examples/real_benchmark.py
| Method | Accuracy | Cost | Savings |
|---|---|---|---|
| Fixed 1024p | 98.8% | 385.8 | — |
| ACIES | 90.8% | 93.6 | 76% |
| Fixed 224p | 82.1% | 76.5 | 80% |
| Random | 95.5% | 149.6 | 61% |
./acies-cli bench --iterations 5000
32,800 runs/sec — 70× faster than Python (476 images/sec)
| Profile | APC Cost | Fixed 1024p | Savings |
|---|---|---|---|
| Default | 260.9 | 448.4 | 42% |
| Jetson Orin | 204.4 | 347.1 | 41% |
| Raspberry Pi 5 | 287.5 | 525.2 | 45% |
| Desktop GPU | 290.6 | 479.0 | 39% |
| Edge TPU | 53.4 | 92.0 | 42% |
python3 test_apc.py
| # | Test | Description | Result |
|---|---|---|---|
| 1 | Base functionality | Accuracy, cost, exploration | ✓ |
| 2 | Hard tasks | High difficulty scenarios | ✓ |
| 3 | Distribution shift | Thompson adaptation | ✓ |
| 4 | Sensor failure | Degraded reliability | ✓ |
| 5 | Hardware profiles | All 5 profiles | ✓ |
| 6 | Stress test | 5,000 iterations | ✓ |
| 7 | Belief math | Bayesian verification | ✓ |
| 8 | Thompson convergence | Posterior accuracy | ✓ |
ACIES/
├── acies/                  # Python package (8 modules)
│   ├── controller.py       # Main APC loop
│   ├── belief.py           # Bayesian belief tracker
│   ├── clarity_learner.py  # Thompson Sampling
│   ├── safety.py           # Risk guarantees
│   ├── conviction.py       # Anti-oscillation
│   ├── change_point.py     # BOCPD shift detection
│   ├── actions.py          # Action space & HW profiles
│   └── accelerator.py      # C++ ctypes wrapper
│
├── cpp/                    # C++ core library
│   ├── belief.h/.cpp       # Belief state
│   ├── clarity_learner.*   # Thompson Sampling
│   ├── acies.h/.cpp        # C API
│   └── Makefile
│
├── core.go                 # Go implementation
├── main.go                 # Go CLI (run/bench/config)
│
├── test_apc.py             # 8 robustness tests
├── examples/               # Benchmarks & demos
├── docs/                   # 9 documentation files
├── assets/                 # Logo & visual identity
├── Dockerfile              # Multi-stage build
└── README.md
| Doc | Description |
|---|---|
| Installation | Setup guide for Python, Go, C++, Docker |
| Architecture | Deep dive into control loop and algorithms |
| Configuration | All configuration parameters |
| CLI Reference | Go CLI commands and flags |
| Python API | Complete Python API reference |
| C++ API | C API for FFI (Python/Go/Rust) |
| Examples | 10 usage examples |
| Benchmarks | Performance results on MNIST |
| Contributing | Development guide |
| Layer | Tech | Performance |
|---|---|---|
| CLI | Go | 32,800 runs/sec |
| Core | Python (stdlib) | 476 images/sec |
| Accelerator | C++ via ctypes | 3-5× Python speed |
| Tests | 8 robustness tests | all passing |
| Benchmark | 5 methods × 5 HW profiles | + MNIST 10k |
| Deploy | Multi-stage Dockerfile | Python + Go + C++ |
See docs/contributing.md.
MIT License — see LICENSE.
@software{acies2026,
  title = {ACIES: Adaptive Perception Control},
  year = {2026},
  url = {https://github.com/NICE-DEV226/ACIES}
}
Download counts and popularity will appear here as the collector receives them.
| Version | Published | Direct dependencies | Open version |
|---|---|---|---|
| 0.1.4 | 4 Sept 2026 | 1 |
This describes our collected data; it is not a security assessment.
Observed since 20 Oct, 18:14 UTC
No superseded metadata states collected. Unchanged observations do not create new revisions.
package:5e49e77a9796e2083d5251688406744b1db6182412137c959eb181c3a053f8fc