
 Repository
Current collected state Current
Observed since 20 Oct, 18:42 UTC
No superseded metadata states collected. Unchanged observations do not create new revisions.
Python interface for controlling various robotic actuators
Defines a package to make it easy and performant to control actuators.
[!WARNING] The Python bindings for this package are currently in an experimental state and may be unstable or subject to breaking changes.
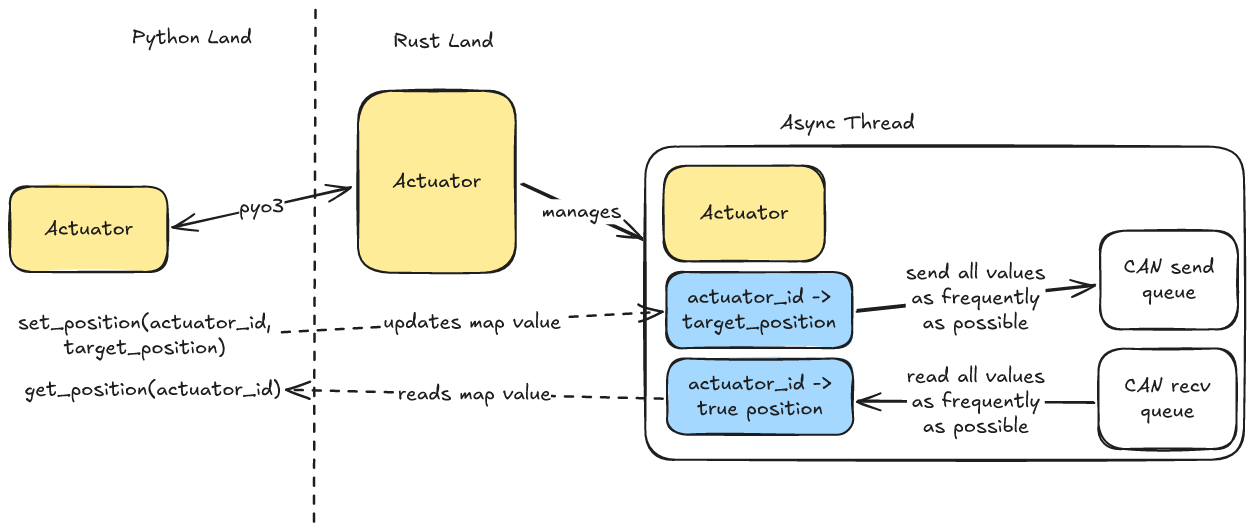
See the documentation here for instructions on getting started with this package.
This package requires Linux for building due to dependencies on Linux-specific CAN bus libraries.
If you're developing on other platforms, consider using a Linux virtual machine or container for building.
Download counts and popularity will appear here as the collector receives them.
| Version | Published | Direct dependencies | Open version |
|---|---|---|---|
| 0.3.6 | 11 May 2025 | 7 |
This describes our collected data; it is not a security assessment.
Observed since 20 Oct, 18:42 UTC
No superseded metadata states collected. Unchanged observations do not create new revisions.
package:d36aad4b3c6a6a77ca19a28e9229ca032ce9cdda6f5af72271aa8da11314ded5