
 Repository
Current collected state Current
Observed since 20 Oct, 19:58 UTC
No superseded metadata states collected. Unchanged observations do not create new revisions.

An advanced PID controller in Python. The derivative term can also be used in practice thanks to built-in first-order filter. Detailed information can be found here.
Usage is very simple:
from advanced_pid import PID

# Create PID controller
pid = PID(Kp=2.0, Ki=0.1, Kd=1.0, Tf=0.05)

# Control loop
while True:
    # Get current measurement from system
    timestamp, measurement = system.get_measurement()

    # Calculate control signal by using PID controller
    reference = 1.0
    control = pid(timestamp, reference - measurement)

    # Feed control signal to system
    system.set_input(control)
Complete API documentation can be found here.
Biggest advantage of advanced-pid, the derivative term has a built-in first-order
filter.
advanced-pid package includes a toy mass-spring-damper system model for testing:
from advanced_pid import PID
from advanced_pid.models import MassSpringDamper
from matplotlib import pyplot as plt
from numpy import diff

# Create a mass-spring-damper system model
system = MassSpringDamper(mass=1.0, spring_const=1.0, damping_const=0.2)
system.set_initial_value(initial_position=1.0, initial_velocity=0.0)

# Create PID controller
pid = PID(Kp=1.0, Ki=0.0, Kd=2.0, Tf=0.5)

# Control loop
time, meas, cont = [], [], []
for i in range(800):
    # Get current measurement from system
    timestamp, measurement = system.get_measurement()

    # Calculate control signal by using PID controller
    control = pid(timestamp, -measurement)

    # Feed control signal to system
    system.set_input(control)

    # Record for plotting
    time.append(timestamp)
    meas.append(measurement)
    cont.append(control)

# Plot result
fig, (ax1, ax2, ax3) = plt.subplots(3, 1)
fig.suptitle('Mass-Spring-Damper system')
ax1.set_ylabel('Measured Position [m]')
ax1.plot(time, meas, 'b')
ax1.grid()
ax2.set_ylabel('Force [N]')
ax2.plot(time, cont, 'g')
ax2.grid()
ax3.set_xlabel('Time [s]')
ax3.set_ylabel('Derivative Term')
ax3.plot(time[1:], diff(meas)/diff(time), 'r')
ax3.grid()
plt.show()
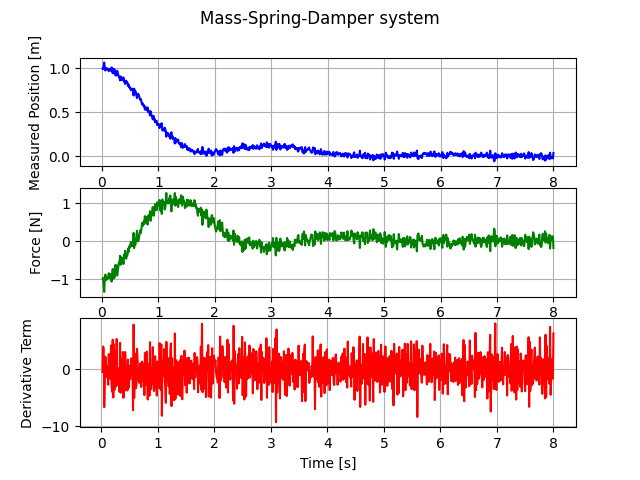
As It can be seen in the figure, derivative term cannot be use without a filter:
To install, run:
pip3 install advanced-pid
To run tests, run:
python -m unittest tests.test_pid
Licensed under the MIT License.
Download counts and popularity will appear here as the collector receives them.
| Version | Published | Direct dependencies | Open version |
|---|---|---|---|
| 0.0.8 | 29 Jun 2022 | 0 |
This describes our collected data; it is not a security assessment.
Shared repository data · GitHub
Public sponsor counts have not been collected. These signals belong to the repository owner.
github · 1 observations shown. Missing days are unknown.
| Date / source period | Value | Observed at |
|---|---|---|
| 2026-10-22 | 1 | 2026-10-22T21:39:05.6237833Z |
Observed since 20 Oct, 19:58 UTC
No superseded metadata states collected. Unchanged observations do not create new revisions.
package:fb9ca70e4c4f6afdcb4926fd693f758463a6411c30adf8407ecad9c0e2e7e09e