
 Repository
Current collected state Current
Observed since 20 Oct, 19:07 UTC
No superseded metadata states collected. Unchanged observations do not create new revisions.
adaptive-oscillator
Adaptive oscillator for gait phase identification.


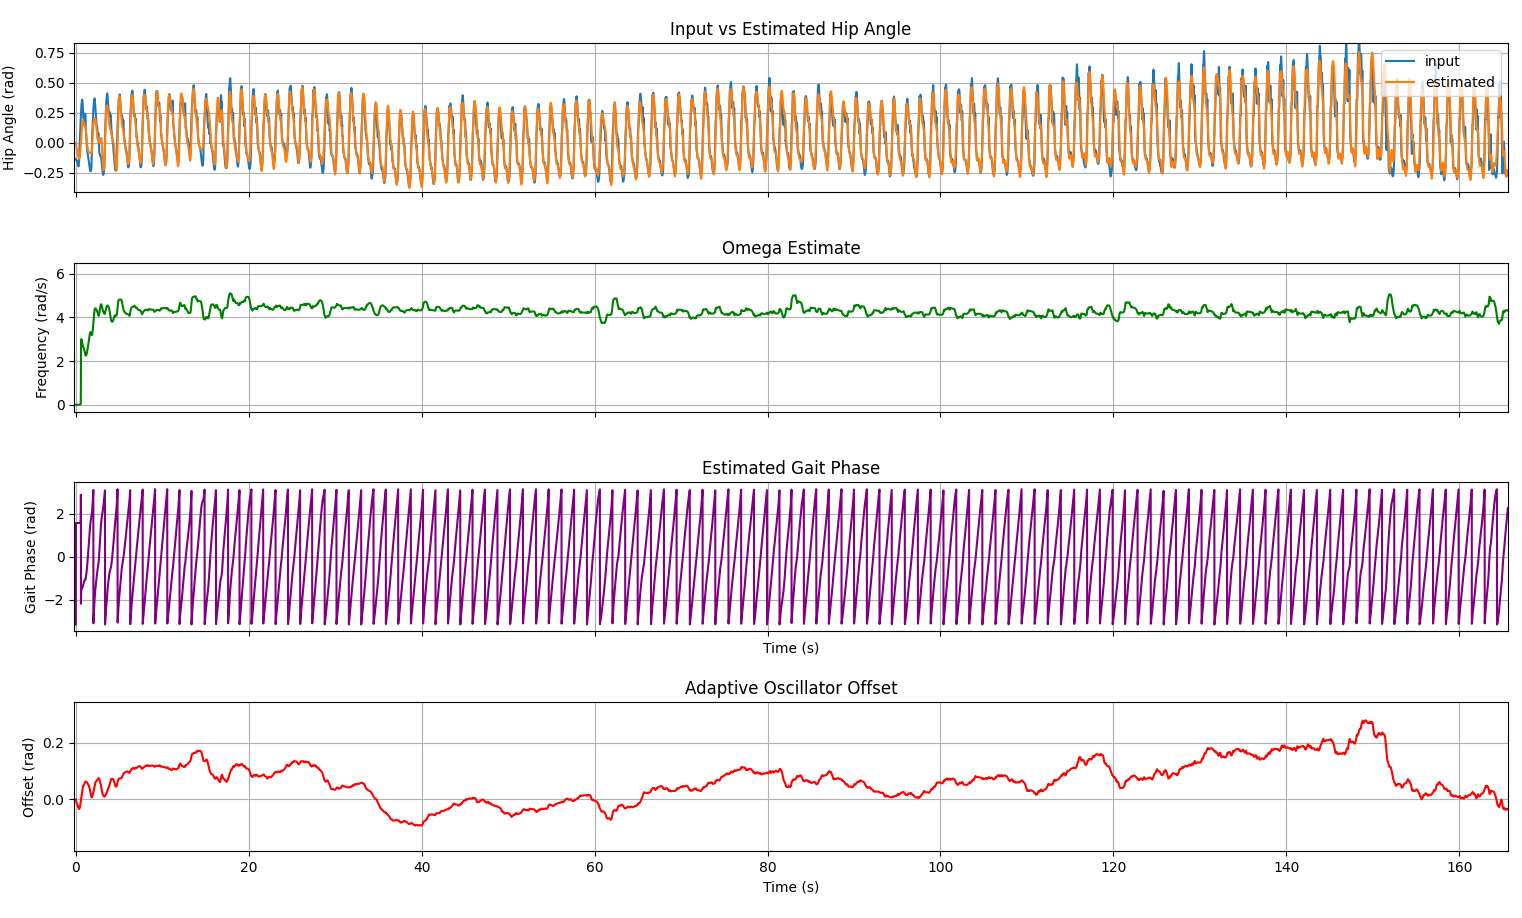
AOs can be described as a mathematical tool able to synchronize with a rhythmic and periodic signal by continuously estimating its fundamental features (i.e. frequency, amplitude, phase, and offset). For their properties, AOs found applications in gait pattern estimation strategies, where they are used to mimic the dynamics of the neuromechanical oscillators in charge of the rhythmical human locomotion. In addition, as gait periodicity can be captured by sensors recording joint kinematics, their application does not require a complex sensory network.
To install the library run: pip install adaptive-oscillator
make init to create the virtual environment and install dependenciesmake format to format the code and check for errorsmake test to run the test suitemake clean to delete the temporary files and directoriespoetry publish --build to build and publish to https://pypi.org/project/adaptive-oscillator"""Basic usage for the adaptive oscillator."""
def main() -> None:
"""Run a simple demonstration."""
# Initialize system
controller = AOController(show_plots=True)
while True:
t, x_axis_angle, x_axis_vel = read_from_sensor()
th = np.deg2rad(x_axis_angle)
dth = np.deg2rad(x_axis_vel)
controller.step(t=t, x=th, x_dot=dth)
controller.plot_results()
if __name__ == "__main__":
main()
The plot below shows the results being plotted in real time.
The files and folders below are used for development purposes. This repo tree can be updated with make tree.
├── docs
│   ├── adaptive oscillators.pdf
│   └── results.png
├── src
│   └── adaptive_oscillator
│       ├── log_files
│       │   ├── __init__.py
│       │   ├── main.py
│       │   └── parser.py
│       ├── utils
│       │   ├── __init__.py
│       │   ├── log_utils.py
│       │   ├── plot_utils.py
│       │   └── time_utils.py
│       ├── __init__.py
│       ├── __main__.py
│       ├── base_classes.py
│       ├── controller.py
│       ├── definitions.py
│       └── oscillator.py
├── tests
│   ├── __init__.py
│   ├── adaptive_oscillator_test.py
│   ├── base_classes_test.py
│   ├── conftest.py
│   ├── controller_test.py
│   ├── parser_utils_test.py
│   ├── plot_utils_test.py
│   ├── time_utils_test.py
│   └── utils_for_test.py
├── .gitignore
├── .pre-commit-config.yaml
├── CONTRIBUTING.md
├── LICENSE
├── Makefile
├── README.md
├── poetry.lock
├── pyproject.toml
└── repo_tree.py
Download counts and popularity will appear here as the collector receives them.
| Package / target | Requirement | Relationship |
|---|---|---|
numpyEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | numpy<3.0.0,>=2.2.3 | runtime |
pytestEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | pytest<9.0.0,>=8.3.5 | runtime |
pytest-covEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | pytest-cov<7.0.0,>=6.0.0 | runtime |
loguruEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | loguru<0.8.0,>=0.7.3 | runtime |
pre-commitEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | pre-commit<5.0.0,>=4.1.0 | runtime |
poetry-coreEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | poetry-core<3.0.0,>=2.1.2 | runtime |
pandasEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | pandas<3.0.0,>=2.3.0 | runtime |
matplotlibEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | matplotlib<4.0.0,>=3.10.3 | runtime |
scipyEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | scipy<2.0.0,>=1.15.3 | runtime |
plotlyEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | plotly<7.0.0,>=6.2.0 | runtime |
dashEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | dash<4.0.0,>=3.1.1 | runtime |
py-imuEnvironment{
"extras": "",
"marker": null,
"requires_python": "<3.13,>=3.11",
"evaluation": "NOT_EVALUATED"
} | py-imu<0.2.0,>=0.1.0 | runtime |
bdist_wheel · 22.08 KB · Python py3
sdist · 18.78 KB · Python source
Shared repository data · GitHub
Observed since 20 Oct, 19:07 UTC
No superseded metadata states collected. Unchanged observations do not create new revisions.
package_version:55f66e3ba7bd7d1e66a5c8ea3cbc33ee587796e7a2c6a6f5f2774c0501a496c2